Sitemap
A list of all the posts and pages found on the site. For you robots out there, there is an XML version available for digesting as well.
Pages
Posts
Future Blog Post
Published:
This post will show up by default. To disable scheduling of future posts, edit config.yml and set future: false.
Blog Post number 4
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Blog Post number 3
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Blog Post number 2
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Blog Post number 1
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
portfolio
Robotic Testbed for Research on Dynamic Legged Locomotion on Yielding Terrain
Published:
I designed and built this robot leg to serve as an experimental testbed for the latter half of my doctoral research.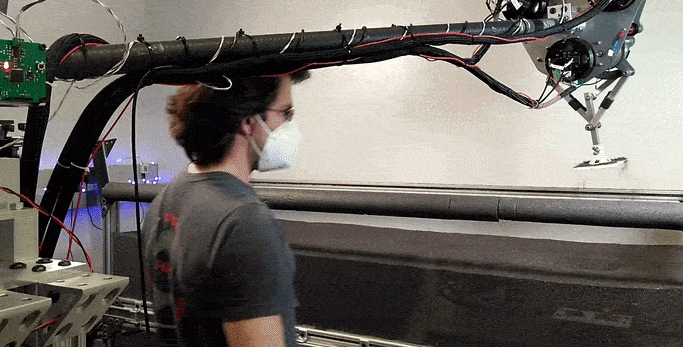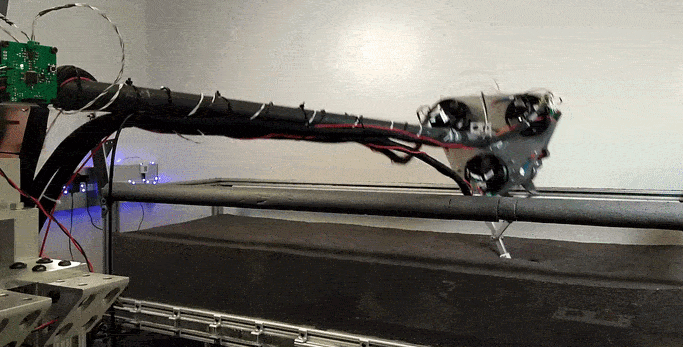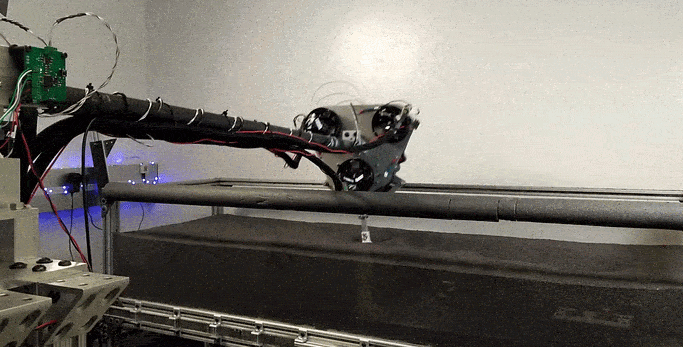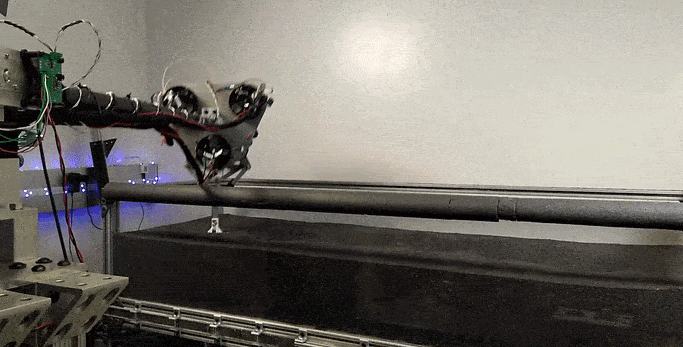
Fast(er) 3D Resistive Force Theory
Published:
This is a vectorized implementation of 3D resistive force theory (Agarwal et al., PNAS 2023) with support for custom intruder geometries.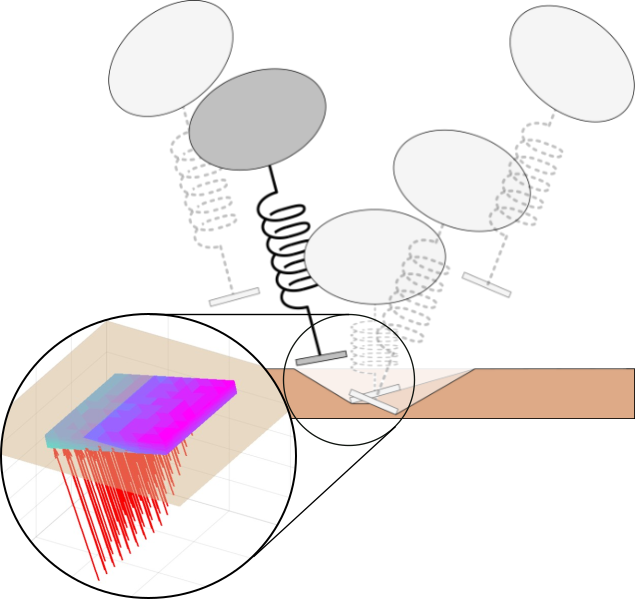
Rigid-Body Mechanics on SE(3) with Impacts
Published:
This project uses a geometric integrator and event detection to simulate an American football tumbling and bouncing on a hard surface with friction.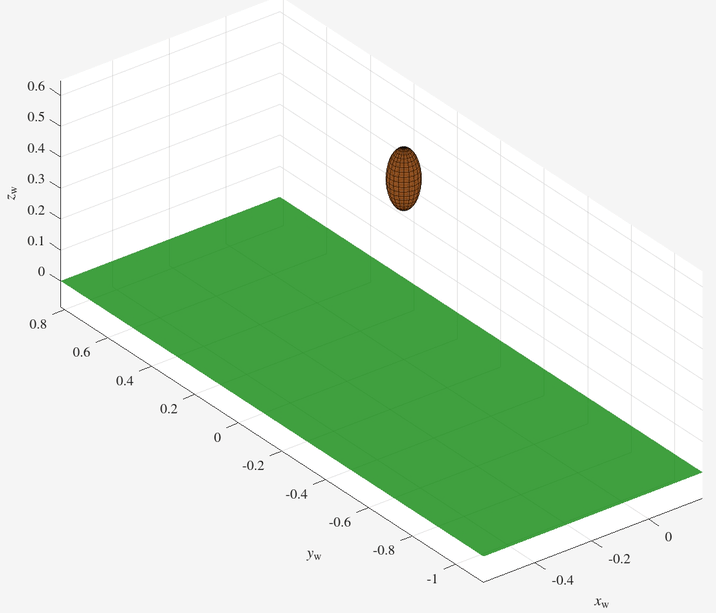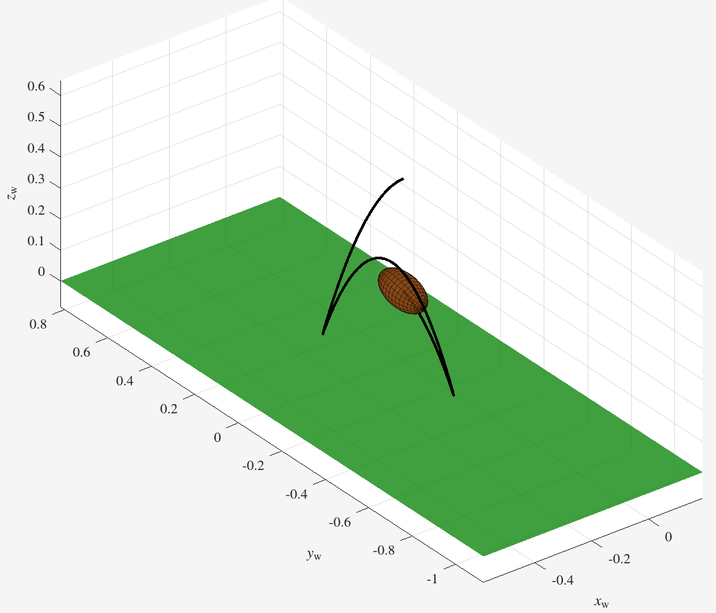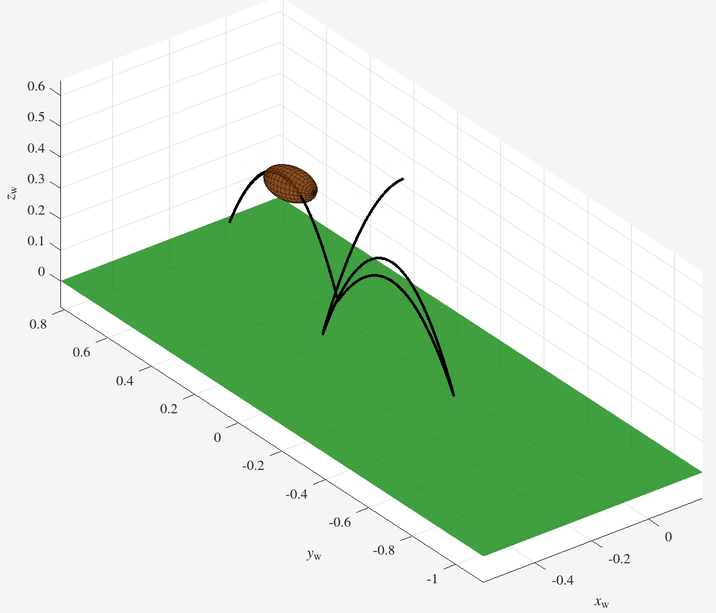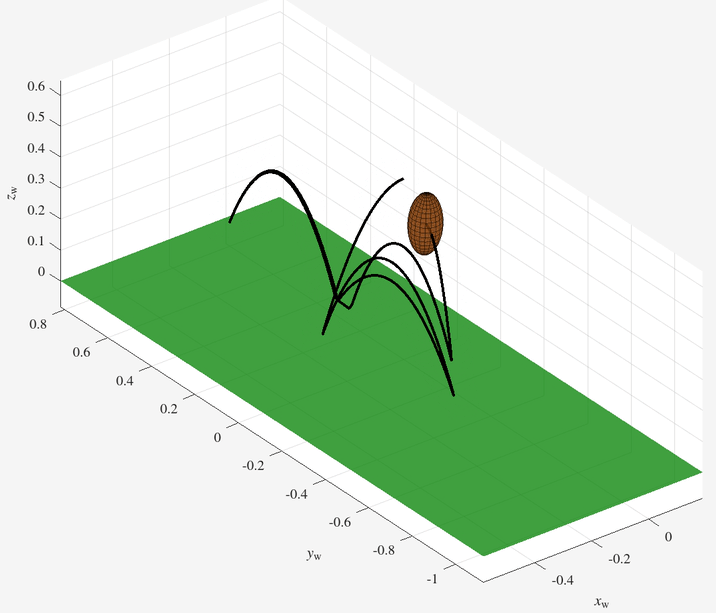
publications
The Soft-Landing Problem: Minimizing Energy Loss by a Legged Robot Impacting Yielding Terrain
Published in IEEE Transactions on Robotics, 2020
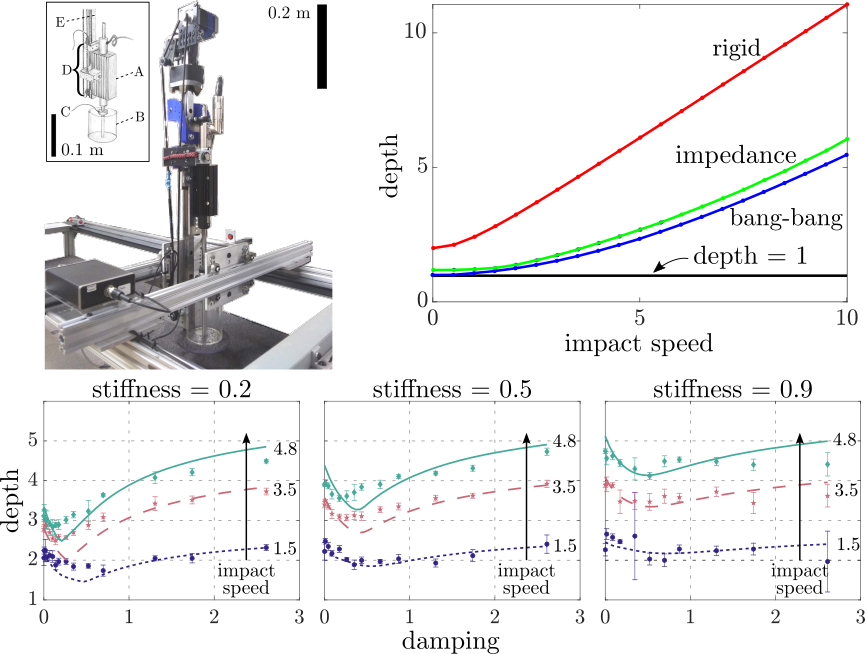
This paper examines the so-called "soft-landing problem" for a robot hopping on yielding substrates (e.g., granular media): given some impact momentum, bring the robot to rest while minimizing foot penetration depth. I derive the theoretically optimal landing strategy in terms of minimizing energy dissipated by the ground and compare it to the best case achievable with simple impedance control, which turns out to perform nearly as well. I validate these results with systematic experiments using a custom-built robot impacting a prepared bed of granular media.
Recommended citation: D. J. Lynch, K. M. Lynch and P. B. Umbanhowar, "The Soft-Landing Problem: Minimizing Energy Loss by a Legged Robot Impacting Yielding Terrain," in IEEE Robotics and Automation Letters, vol. 5, no. 2, pp. 3658-3665, April 2020.
Download Paper
Efficient, Responsive, and Robust Hopping on Deformable Terrain
Published in IEEE Transactions on Robotics, 2024
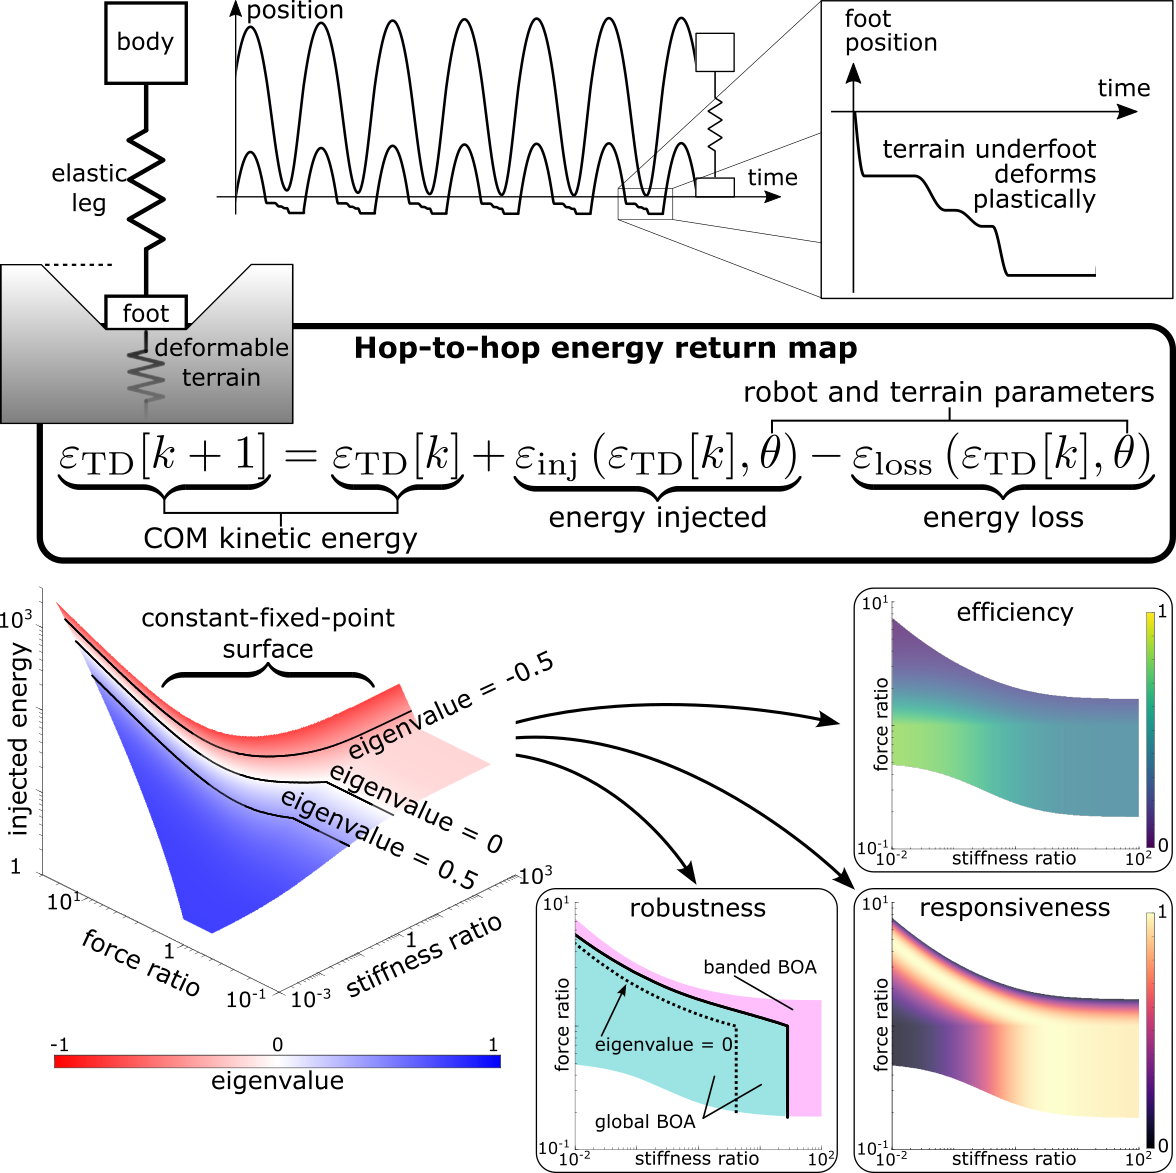
This paper addresses the hop-to-hop energy dynamics of a simple vertically-constrained monopedal hopping robot. I examine how the energy dynamics is affected by irrecoverable energy loss through plastic terrain deformation underfoot, which in turn depends on the foot depth and the forces the robot applies during stance. Vertical hopping provides a simple setting in which to study the interplay between foot-ground interaction, plastic terrain deformation, and hop-to-hop energy dynamics.
Recommended citation: D. J. Lynch, J. L. Pusey, S. W. Gart, P. B. Umbanhowar and K. M. Lynch. "Efficient, Responsive, and Robust Hopping on Deformable Terrain," in IEEE Transactions on Robotics, vol. 41, pp. 782-800, 2025.
Download Paper
A Template-and-Anchor Approach to Dynamic Legged Locomotion on Yielding Terrain
Published in N/A, 2026
talks
Soft Landing of a Legged Robot on Yielding Terrain
Published:
I delivered an oral presentation of preliminary results on the so-called “soft landing problem” of how to minimize energy loss from ground deformation when a legged robot impact yielding terrain (e.g., granular media). These preliminary results led to a journal paper, published the following year in IEEE Robotics and Automation Letters.
Soft Landing of a Legged Robot on Yielding Terrain
Published:
I delivered a 2-minute lightning talk followed by a poster presentation of preliminary results on the so-called “soft landing problem” of how to minimize energy loss from ground deformation when a legged robot impact yielding terrain (e.g., granular media). These preliminary results led to a journal paper, published the following year in IEEE Robotics and Automation Letters.
The Soft-Landing Problem: Minimizing Energy Loss by a Legged Robot Impacting Yielding Terrain
Published:
I delivered a virtual oral presentation followed by a virtual poster session for my RA-L paper “The Soft-Landing Problem: Minimizing Energy Loss by a Legged Robot Impacting Yielding Terrain”. You can watch a video of this presentation on YouTube.
A Motion-Planning Framework for Dynamic Monopedal Locomotion on Deformable Terrain
Published:
I delivered an online oral presentation on research into planning period-one hopping gaits on deformable (i.e., yielding) terrain, using resistive force theory to model the physics of planar foot-ground interaction and using direct collocation trajectory optimization to generate feasible gaits. You can watch a video of this presentation on YouTube. This work taught me about the potential and limitations of trajectory optimization. I am using it as a starting point for some of the methods going into another journal paper on planning and control for dynamic locomotion on complex terrain via reduced-order/simplified models, currently in preparation.
Towards SLIP-Inspired Hopping on Yielding Terrain
Published:
I delivered an oral presentation of (very) preliminary results on research into generalizing the spring-loaded inverted pendulum (SLIP) template to yielding terrain. These preliminary results showed that the dynamics of the coupled robot-terrain system can be quite rich (i.e., complex!) and deserving of closer study, which led to another talk at the following year’s APS March Meeting and, eventually, culminated in a journal paper, published in IEEE Transaction in Robotics.
Hopping on Deformable Terrain with State-Based Switching: Dynamics and Implications for Robot Design
Published:
I delivered an oral presentation of preliminary results on the nonlinear dynamics of a simple spring-legged monopedal robot hopping on deformable (i.e., yielding) terrain. These preliminary results led to a journal paper, published late the following year in IEEE Transaction in Robotics.
A Template-and-Anchor Approach to Stable Sagittal-Plane Legged Locomotion on Yielding Terrain
Published:
I delivered an oral presentation of preliminary results on dynamic planar hopping on yielding terrain using a reduced-order model of foot-ground interaction and tools from nonlinear dynamics. I am developing these preliminary results into a journal paper, currently in preparation.
Efficient, Responsive, and Robust Hopping on Deformable Terrain
Published:
I delivered an oral presentation followed by a poster session for my T-RO paper “Efficient, Responsive, and Robust Hopping on Deformable Terrain”.
teaching
Teaching Assistant
Department of Mechanical Engineering, Northwestern University
I have worked as a teaching assistant (TA) for 4 different courses (and a total of 9 different offerings) at Northwestern University, from 2019 to 2026.
- Robotic Manipulation, ME 449: Fall 2026, Fall 2022. Instructor: Prof. Kevin Lynch
- Robot Design Studio, ME 495: Winter-Spring 2020, Winter-Spring 2019. Instructors: Prof. Ed Colgate and Billie Strong (2020); Dr. Ron Worth (2019)
- Introduction to Mechatronics, ME 333: Winter 2021. Instructor: Nick Marchuk
- Scientific and Embedded Programming in Python, ME 224: Spring 2021, Fall 2020, Spring 2020, Fall 2019. Instructors: Prof. Michael Peshkin (Spring 20xx) and Prof. Malcolm MacIver (Fall 20xx)
Volunteer Teacher
Splash at Northwestern (Education Outreach), Northwestern University
In 2022 and 2023, I volunteered as a teacher for Splash at Northwestern, an education outreach program dedicated to providing unique and fun learning opportunities to high school students in the greater Chicago area, especially students coming from underrepresented backgrounds. Each year, I designed and taught a course that applied various topics in mathematics to aspects of real life: ecology (2022) and music (2023).
- Rabbits and Foxes, Butterflies and Tornadoes, and Chaos (2022)
- The Mathematics of Modern Musical Harmony (2023)