Publications

You can also find my articles on my Google Scholar profile.

Journal Articles


Efficient, Responsive, and Robust Hopping on Deformable Terrain

Published in IEEE Transactions on Robotics, 2024
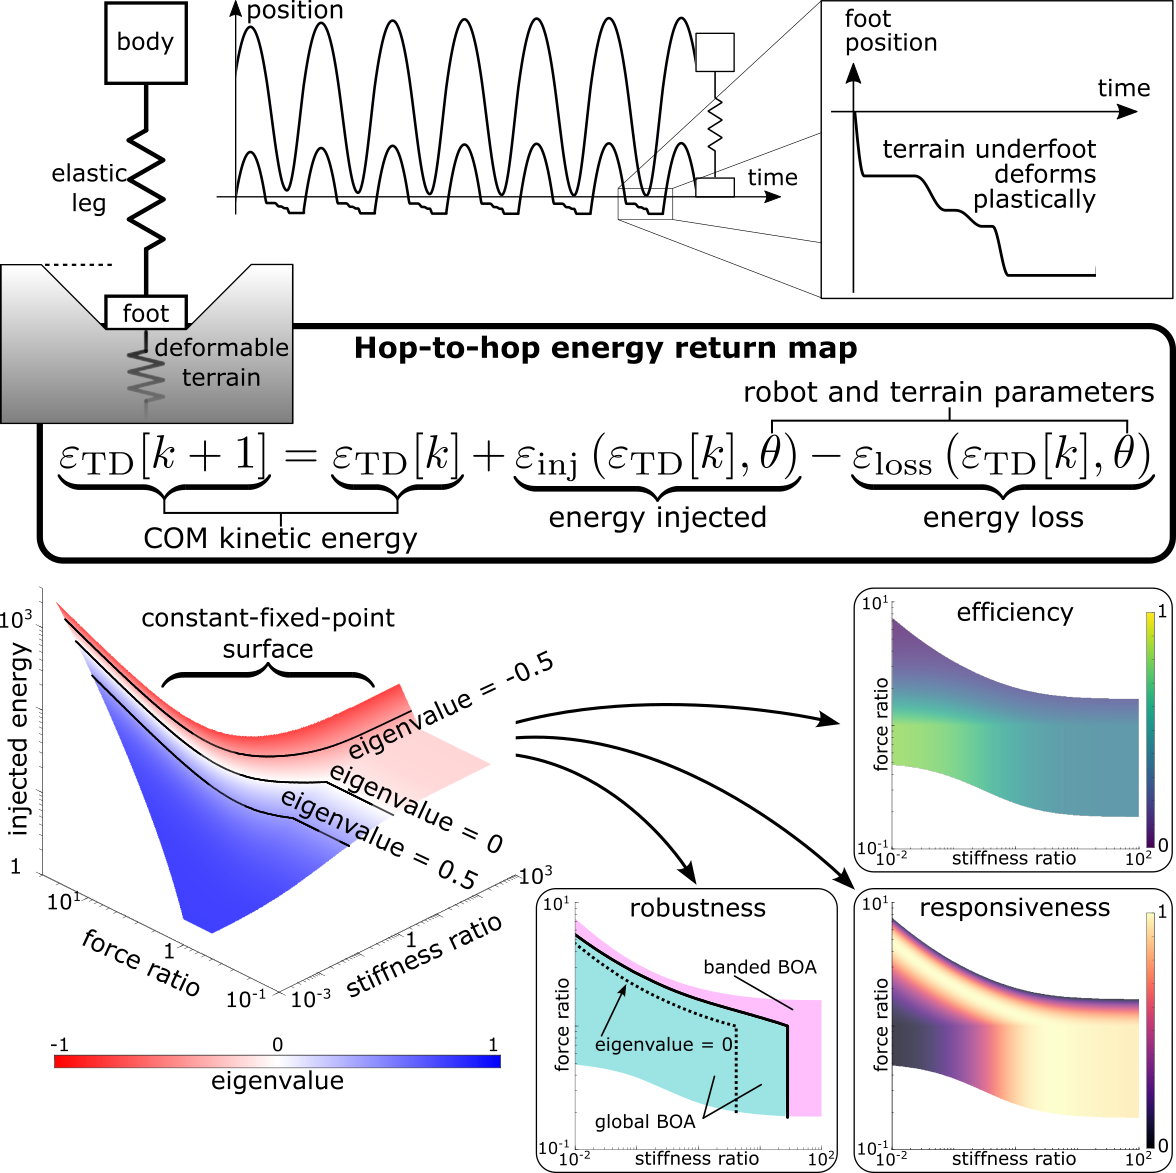


This paper addresses the hop-to-hop energy dynamics of a simple vertically-constrained monopedal hopping robot. I examine how the energy dynamics is affected by irrecoverable energy loss through plastic terrain deformation underfoot, which in turn depends on the foot depth and the forces the robot applies during stance. Vertical hopping provides a simple setting in which to study the interplay between foot-ground interaction, plastic terrain deformation, and hop-to-hop energy dynamics.

Recommended citation: D. J. Lynch, J. L. Pusey, S. W. Gart, P. B. Umbanhowar and K. M. Lynch. "Efficient, Responsive, and Robust Hopping on Deformable Terrain," in IEEE Transactions on Robotics, vol. 41, pp. 782-800, 2025.
Download Paper
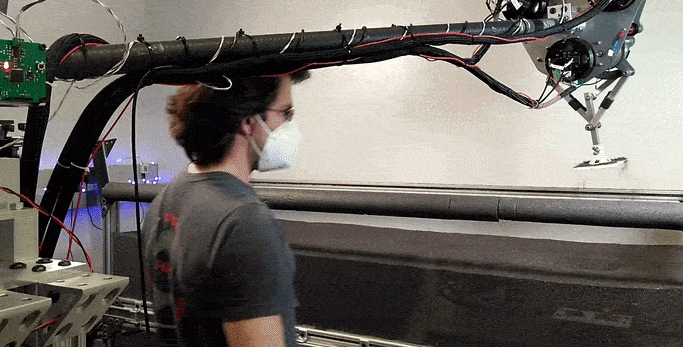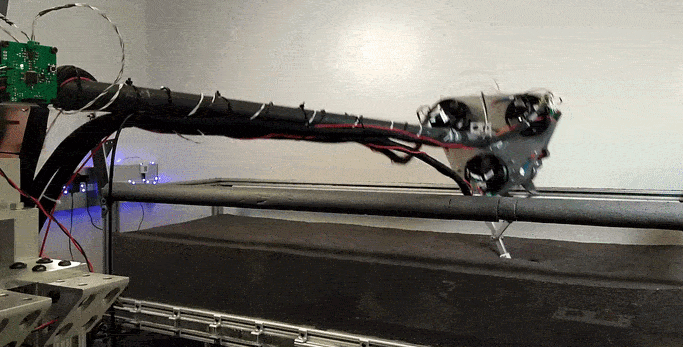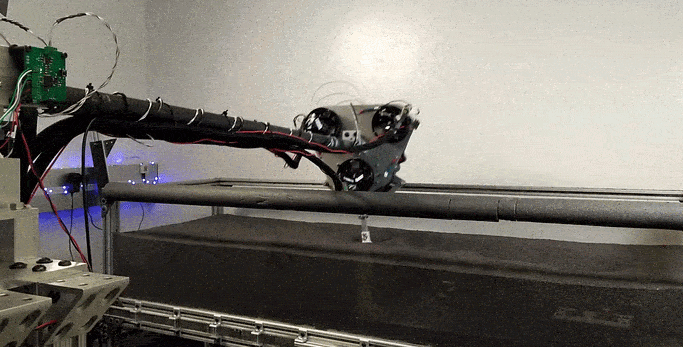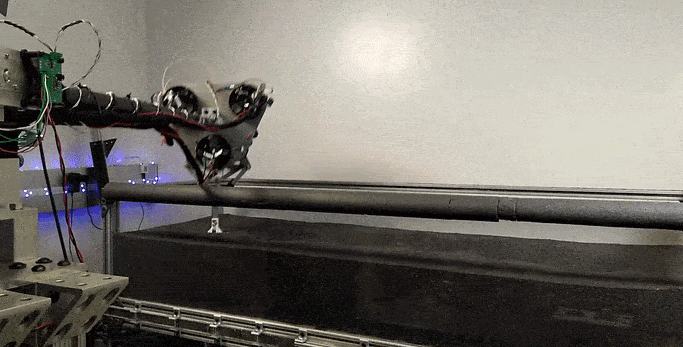
The Soft-Landing Problem: Minimizing Energy Loss by a Legged Robot Impacting Yielding Terrain

Published in IEEE Transactions on Robotics, 2020


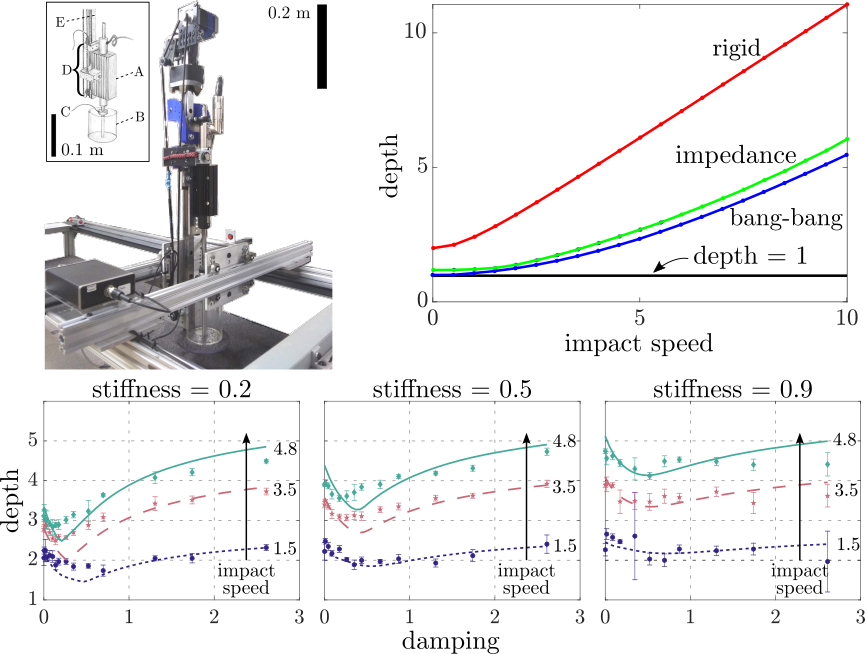
This paper examines the so-called "soft-landing problem" for a robot hopping on yielding substrates (e.g., granular media): given some impact momentum, bring the robot to rest while minimizing foot penetration depth. I derive the theoretically optimal landing strategy in terms of minimizing energy dissipated by the ground and compare it to the best case achievable with simple impedance control, which turns out to perform nearly as well. I validate these results with systematic experiments using a custom-built robot impacting a prepared bed of granular media.

Recommended citation: D. J. Lynch, K. M. Lynch and P. B. Umbanhowar, "The Soft-Landing Problem: Minimizing Energy Loss by a Legged Robot Impacting Yielding Terrain," in IEEE Robotics and Automation Letters, vol. 5, no. 2, pp. 3658-3665, April 2020.
Download Paper

In Preparation