Robotic Testbed for Research on Dynamic Legged Locomotion on Yielding Terrain
Published:
I designed and built this robot leg to serve as an experimental testbed for the latter half of my doctoral research.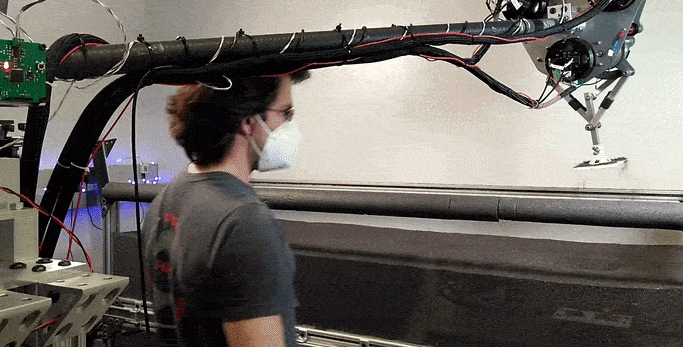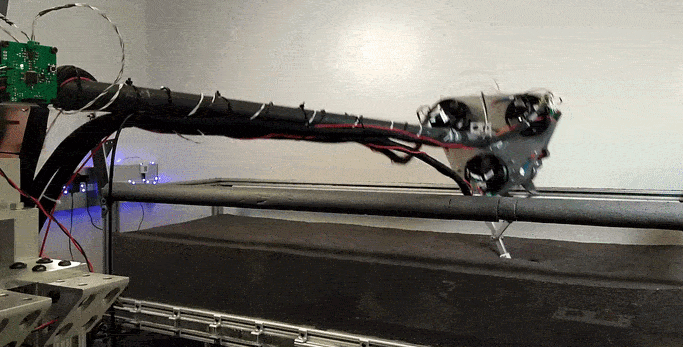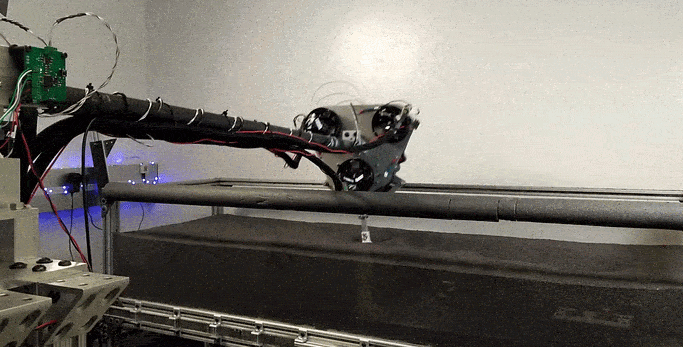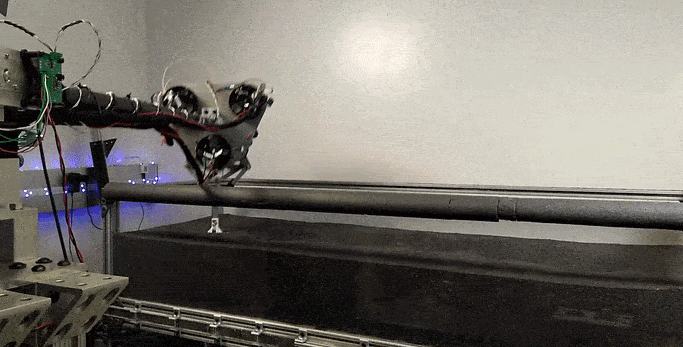
Published:
I designed and built this robot leg to serve as an experimental testbed for the latter half of my doctoral research.
Published:
This is a vectorized implementation of 3D resistive force theory (Agarwal et al., PNAS 2023) with support for custom intruder geometries.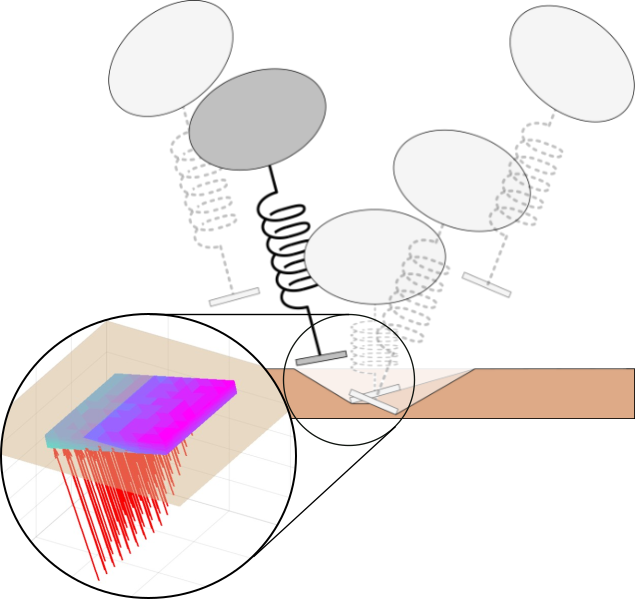
Published:
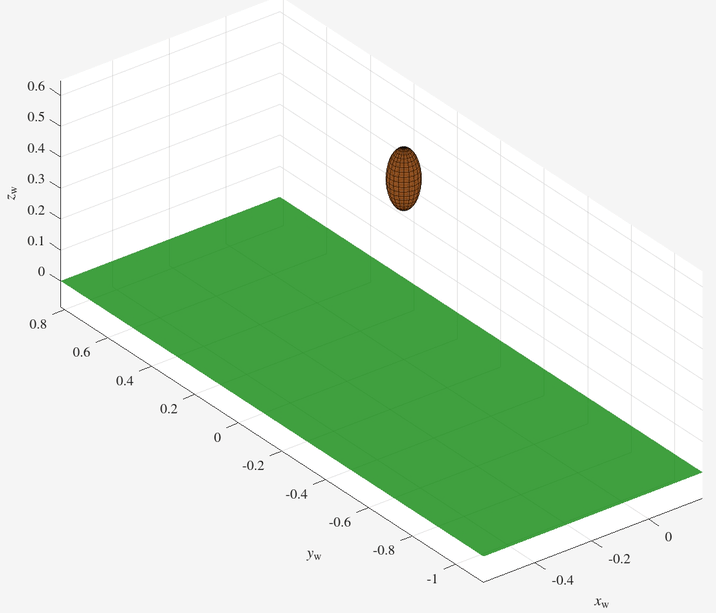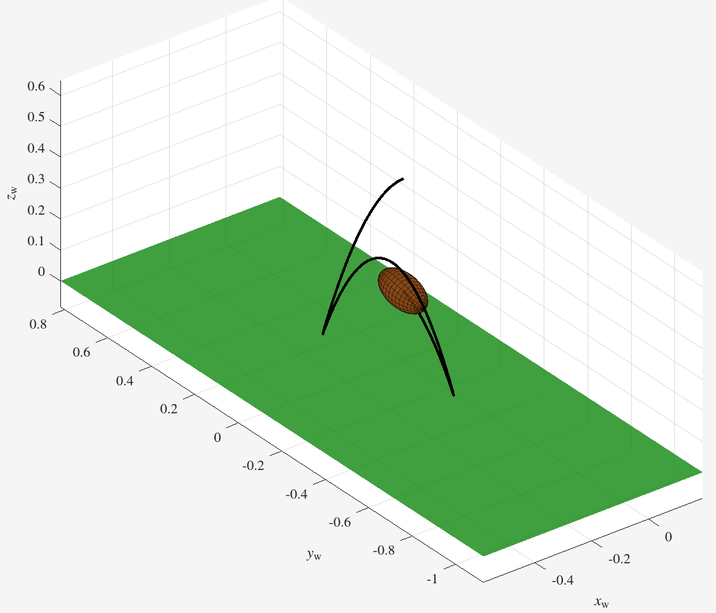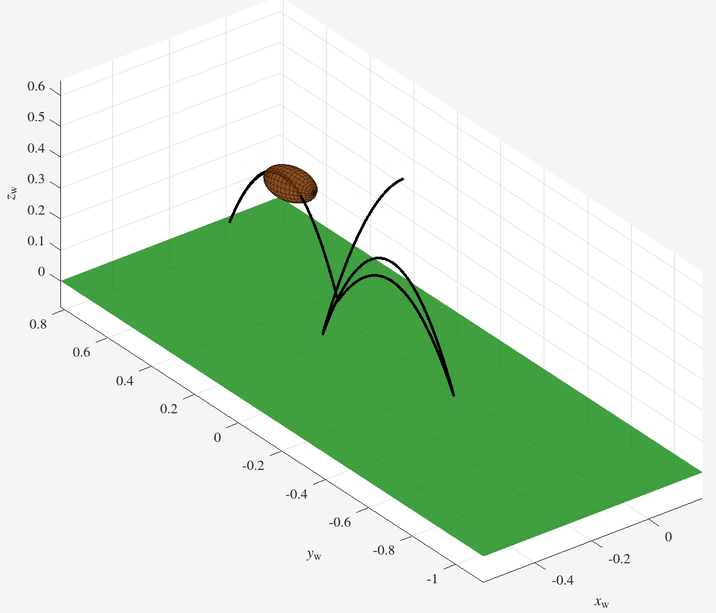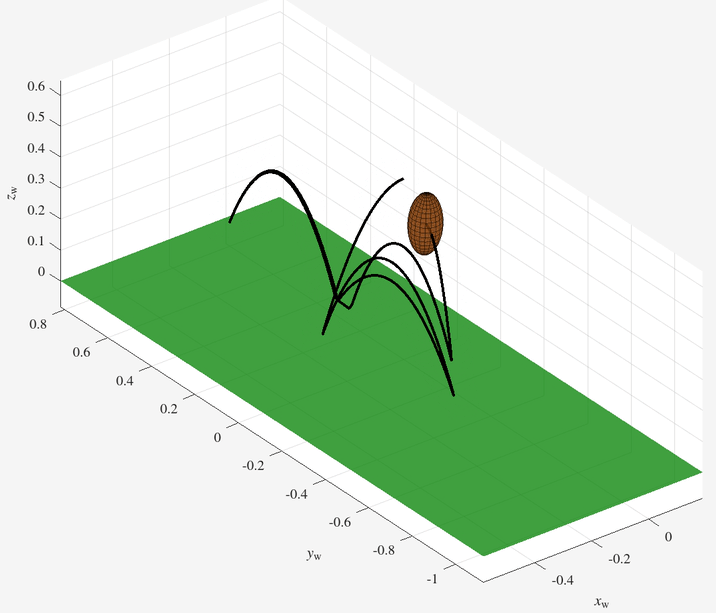
This project uses a geometric integrator and event detection to simulate an American football tumbling and bouncing on a hard surface with friction.